HRI 2026 Peer-reviewed
RECS: LSTM-Based Cognitive Status Estimation for Human-Robot Interaction
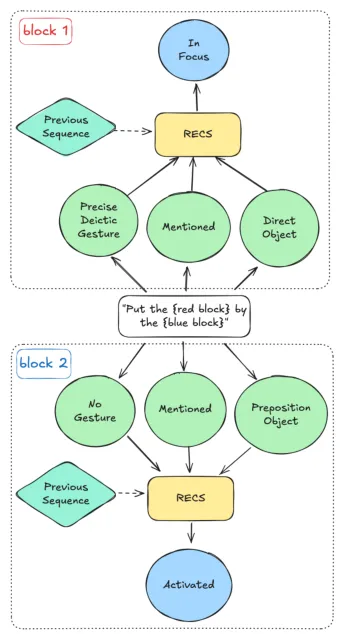
A model that combines language and gestures to help robots estimate which objects a person is thinking about or aware of.
Higger, M., Wang, Z., Rygina, P., Ferreira Bezerra, L., Daigler, L., Aloia, Z., Wu, S., Pandey, I., Chen, A., Williams, T. (2026). Proceedings of the 21st ACM/IEEE International Conference on Human-Robot Interaction.
View citation
@inproceedings{higger2026recs,
  author = {Higger, Mark and Wang, Zhuoyi and Rygina, Polina and Ferreira Bezerra, Lara and Daigler, Logan and Aloia, Zane and Wu, Sheena and Pandey, Ishani and Chen, Amanda and Williams, Tom},
  title = {{RECS}: {LSTM}-Based Cognitive Status Estimation for Human-Robot Interaction},
  booktitle = {Proceedings of the 21st ACM/IEEE International Conference on Human-Robot Interaction},
  year = {2026},
  pages = {590--597},
  doi = {10.1145/3757279.3785597}
}